
在Blender中为自己摆出第一人称手臂和步枪的空间测量答案,在MCP上。
概览
在Blender中为第一人称手臂和步枪摆姿势的空间测量答案。 模型在通过图片判断三维空间方面很弱:比如步枪哪一面朝向眼睛,手指是否插在机匣内,枪械的任何转动是否能显示弹壳抛出口。Pose Lab 则给出模型编号。它报告命名帧中的位置以及任何物体的穿透深度。它测量表面面向眼睛的正向以及眼睛能看到的内容。它的求解器搜索步枪对目标的移动,并报告哪些目标无法通过。对于动画,它逐帧扫描片段,对照相同的检查,修正失败的部分。 我是在手工制作第一人称射击游戏的膛室检查时建造的。有一个问题让我用了好几次Blender运行:转动步枪能显示它的弹壳口吗?用Pose Lab只需一个求题。在我游戏的AK装备上,单靠转动60个样本中0个达成目标。这是几何结构的事实:眼睛沿着枪管看。
概述(AI 翻译)
Pose Lab
在Blender中为第一人称手臂和步枪摆姿势的空间测量答案。
模型在通过图片判断三维空间方面很弱:比如步枪哪一面朝向眼睛,手指是否放在里面 机匣,枪械是否能在任何转动中显示其弹壳抛出口。Pose Lab 给出型号。它 报告命名帧中的位置以及任何物体穿透的深度。它测量表面面向眼睛的正直角度, 眼睛所能看到的。其求解器搜索步枪对目标的移动,并报告哪些目标无法实现。对于 动画,它会逐帧扫描片段,对照相同的检查,修正失败的部分。
我是在为第一人称射击游戏手工制作弹膛检查时建造的。一个问题让我用了好几台Blender才答应
运行:转动步枪时能否向眼睛显示弹射口?用Pose Lab只需一次solve呼叫。在我游戏的AK上
仅靠转向,60个样本中0个都达成了目标。这是几何学的事实:眼睛沿着枪管看。
旋转和移动步枪单独达到每个目标,但没有一个400个样本能同时满足四个目标。所以
Check需要一个新的手型,不仅仅是新的步枪姿势。
本页由 AI 翻译,技术细节请以原文为准。
README
以下为原文 README 节选,完整内容请查看原文。
Pose Lab
Measured spatial answers for posing first-person arms and a rifle in Blender.
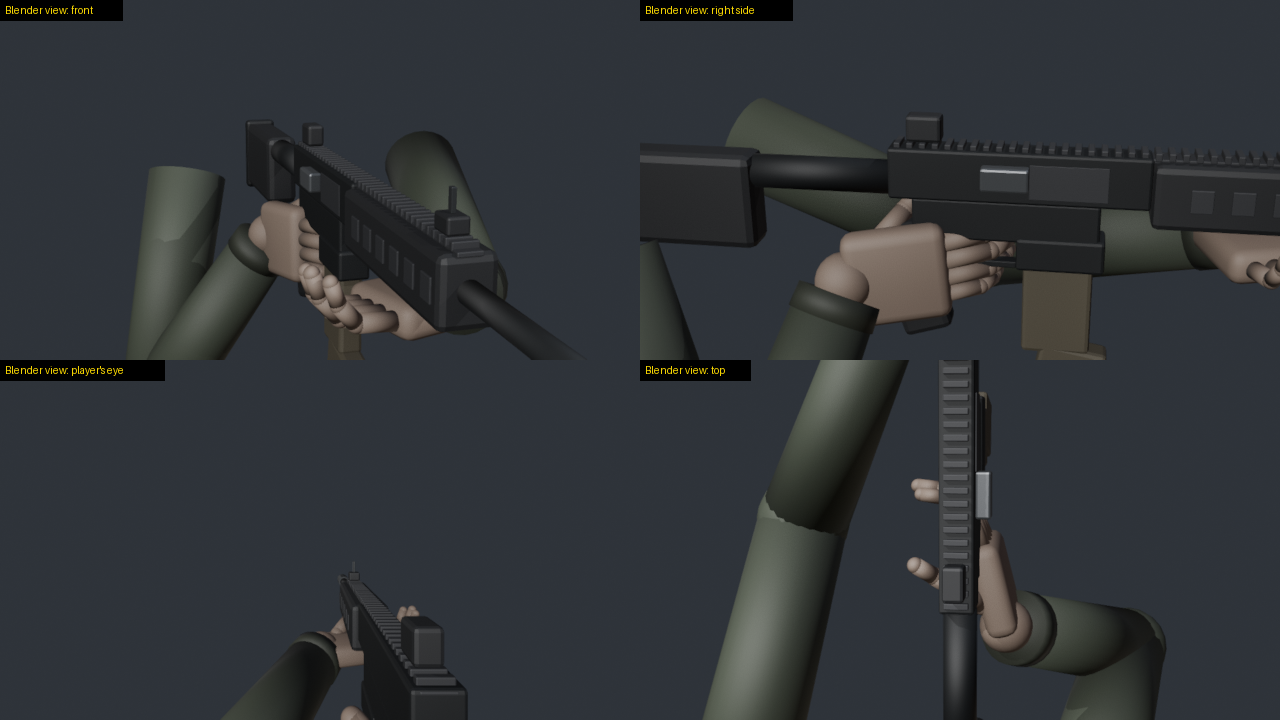
Models are weak at judging 3D space from pictures: which side of a rifle faces the eye, whether a finger sits inside the receiver, whether any turn of the gun can ever show its ejection port. Pose Lab gives a model numbers instead. It reports positions in named frames and how deep anything clips. It measures how squarely a surface faces the eye and what the eye can see. Its solver searches rifle moves against goals and reports which goals no move can meet. For animation, it scans a clip frame by frame against the same checks and mends what fails.
I built it while hand-making chamber checks for my first-person shooter. One question took me several full Blender
runs: can turning the rifle show its ejection port to the eye? With Pose Lab it is one solve call. On my game’s AK
rig, turning alone met the goal in 0 of 60 samples. That is a fact of the geometry: the eye looks along the barrel.
Turning and moving the rifle met each goal on its own, but no sample of 400 met all four goals together. So that
check needs a new hand pose, not only a new rifle position. On the built-in sample rig, turning alone also met the port
goal in 0 of 60 samples, and turning and moving met every goal in 9 s.
What it gives a model
| Tool | Answers |
|---|---|
list_rigs, load_rig, describe |
the rigs, the frames, the sign rules, named points, clips, moving parts |
pose_idle, pose_clip, move_part, snapshot |
put the rig in a pose: a clip at a time, the carrier drawn back, saved poses |
安装
uvx poselab-mcp配置
{
  "mcpServers": {
    "poselab": {
      "command": "uvx",
      "args": ["poselab-mcp"],
      "env": { "POSELAB_BLENDER": "C:/Program Files/Blender Foundation/Blender 5.2/blender.exe" }
    }
  }
}